실리콘 포토닉스 라이다 — 20m를 본 칩, 로봇 센서값을 낮출까Silicon photonics LiDAR: can a 20-metre demonstration lower robot sensor costs?
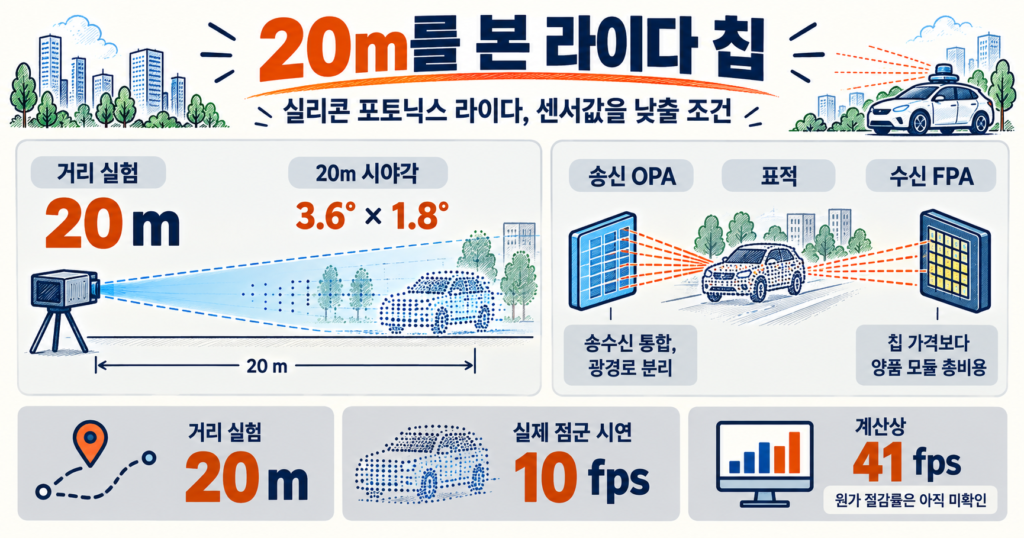
실리콘 포토닉스 라이다가 20m 떨어진 표적을 입체로 읽었습니다. 빛을 보내고 받는 장치를 같은 칩에 넣어, 로봇 센서의 조립비를 낮출 가능성을 보여준 연구입니다. 다만 실제 센서값이 얼마나 내려갈지는 아직 모릅니다. 그 답은 칩 설계보다 공장 현장에 있을 수 있습니다.
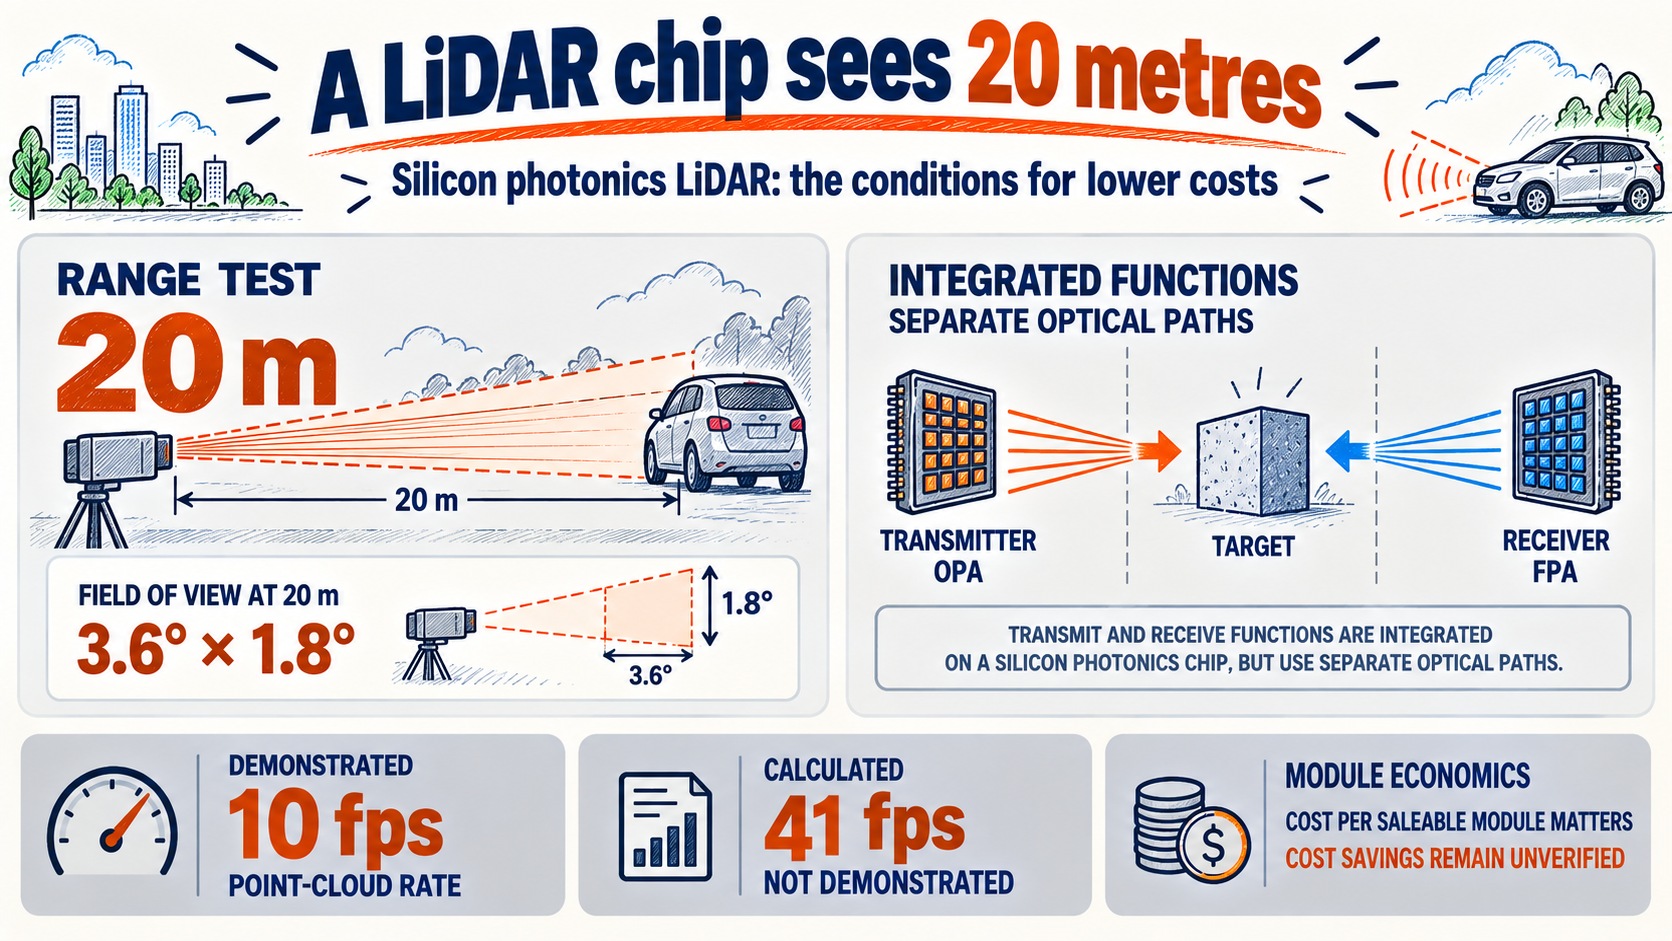
A silicon photonics LiDAR prototype has reconstructed a target 20 metres away. The research integrates the optical transmitter and receiver on one chip, suggesting a route to simpler sensor assembly. It does not establish a cheaper finished product. Understanding that distinction reveals both the engineering achievement and the business opportunity.
근거는 imec와 Tyndall 연구진이 2026년 9월 4일 Nature Communications에 공개한 논문입니다. 심사를 거쳐 채택됐으며, 현재 제공된 자료는 최종 편집 이전의 공개본입니다. 아래에서 실험 결과, 외부 산업 자료, 필자의 경제적 해석을 구분해 읽을 수 있도록 표시했습니다. 관련 원문
실리콘 포토닉스 라이다는 무엇을 바꿨나
라이다는 빛을 쏘고 반사돼 돌아온 신호로 주변 물체의 위치를 알아내는 센서입니다. 실리콘 포토닉스는 반도체 칩 안에 빛이 지나가는 길과 이를 조절하는 소자를 만드는 기술입니다. 전자회로처럼 여러 광학 기능을 함께 제작하려는 접근입니다. 관련 원문
빛이 왕복하는 시간을 재는 방식과 달리, 이번 FMCW 방식은 연속으로 보내는 빛의 주파수를 변화시키고 돌아온 빛을 기준광과 비교합니다. 이 차이에서 거리와 센서 방향으로 접근하거나 멀어지는 속도를 구합니다. 물체가 어느 쪽으로든 움직이는 속도를 전부 읽는다는 뜻은 아닙니다. 관련 원문
칩 라이다 자체가 처음 등장한 것은 아닙니다. 2022년 Nature에도 미세 기계식 스위치를 이용한 실리콘 포토닉스 라이다가 실렸습니다. 따라서 새 연구의 가치는 최초라는 수식어보다, 송신과 수신에 서로 다른 강점을 가진 구조를 한 칩에서 결합한 데 있습니다. 관련 원문
새 설계의 송신부는 여러 빛의 파동을 맞춰 방향을 바꾸는 광학 위상 배열, OPA입니다. 수신부는 렌즈가 모은 반사광을 배열 형태의 검출기로 받는 FPA입니다. 보내는 쪽은 방향 조절을, 받는 쪽은 빛을 모으고 여러 지점을 함께 읽는 역할을 맡습니다. 두 광경로를 분리해 빛의 입출력을 갈라 주는 서큘레이터라는 부품도 없앴습니다. 관련 원문
송신 OPA
빛의 방향 조절
역할
방식 · 파동의 위상 제어
수신 FPA
반사광 수집·병렬 검출
역할
방식 · 렌즈와 검출기 배열
이 설계가 공학적으로 흥미로운 이유는 분업에 있습니다. 잘 보내는 구조와 잘 받는 구조의 요구가 반드시 같지는 않습니다. 서로 다른 역할을 함께 제작할 수 있다면, 모든 기능을 하나의 광학 구조에 맞추느라 생기는 타협을 줄일 여지가 있습니다. 그 여지가 원가 절감으로 이어지는지는 별도의 제조 문제입니다.
20m 시연과 초당 41프레임을 함께 읽으면 안 되는 이유
논문에서 실제 입체 점군, 즉 공간의 점들로 물체를 표현한 영상을 만든 속도는 초당 10프레임입니다. 41프레임은 컴퓨터의 데이터 전송·처리 지연을 줄인 구성을 가정해 시간 배분으로 계산한 가능치입니다. 이미 41프레임짜리 완제품이 작동했다는 의미로 읽으면 성과를 부풀리게 됩니다. 관련 원문
두 실측값 비교가 아닙니다. 41 fps는 컴퓨터 처리·전송 병목 제거를 가정한 시간 배분 계산입니다. 출처: 논문 pp.2,5.
거리에도 조건이 붙습니다. 20m 실험의 시야각은 3.6°×1.8°였습니다. 가까운 1m 시연에서는 16°×8°를 사용했습니다. 시야각은 한 번에 보는 공간의 폭입니다. 더 멀리 보는 조건과 더 넓게 보는 조건을 합쳐 하나의 성능표처럼 소개해서는 안 됩니다. 관련 원문
가까운 거리 시연
1 m
거리
시야각 · 16° × 8°
렌즈 초점거리 · 8 mm
먼 거리 시연
20 m
거리
시야각 · 3.6° × 1.8°
렌즈 초점거리 · 35 mm
또 하나 주의할 숫자는 3.7mW입니다. 밖으로 나온 빛의 출력이며 장치 전체가 소비하는 전기가 아닙니다. 레이저와 신호처리, 온도 제어는 별도로 필요합니다. 논문의 깊이 분해능 5cm도 모든 재질과 환경에서 오차가 그 이내라는 품질보증은 아닙니다. 관련 원문
이 차이는 구매 담당자에게 중요합니다. 창고 통로 전체를 봐야 하는데 센서가 좁은 구역만 본다면, 더 많은 센서를 달거나 설치 방향을 바꿔야 합니다. 작은 칩을 싸게 만들어도 설치 수량이 늘면 전체 시스템 가격은 내려가지 않을 수 있습니다. 여기부터는 논문 결과를 제품 구매 조건에 적용한 해석입니다.
센서값은 칩 가격보다 조립·검사에서 갈릴 수 있습니다
경제적 해석부터 분명히 하겠습니다. 이 논문은 판매가격이나 공장 원가를 제시한 사업성 보고서가 아닙니다. 부품 통합이 제조 과정을 바꿀 수 있다는 연구입니다. 따라서 몇 퍼센트 싸진다고 숫자를 붙이는 대신, 실제로 줄어들 수 있는 작업을 따져야 합니다.
광학 모듈은 부품을 붙이는 것만으로 완성되지 않습니다. 빛이 원하는 경로로 지나가도록 위치를 맞추고, 온도가 변해도 측정값이 유지되는지 확인해야 합니다. 일부 기능의 상대 위치를 칩 제작 단계에서 정할 수 있다면, 조립 현장에서 반복하는 정렬 작업이 줄어들 가능성이 있습니다.
반대로 여러 기능을 한 칩에 넣으면 한 부분의 불량이 더 큰 부품 전체의 손실로 이어질 수 있습니다. 수율은 만든 제품 중 정상 제품의 비율입니다. 통합 칩의 수율이 낮거나 검사 시간이 길어지면, 조립에서 아낀 돈을 불량과 검사비로 다시 쓰게 됩니다.
-
1
칩에 기능 통합
일부 상대 위치를 제작 단계에서 결정
-
2
조립 작업 감소 가능
정렬·연결 작업이 실제 줄었는지 확인
-
3
수율·검사비 반영
불량과 교정 비용이 절감을 상쇄할 수 있음
-
4
양품 모듈 총비용 비교
현장 유지보수까지 포함해 판단
견적을 비교한다면 칩 단가에 패키징·교정·검사·보증 비용을 더한 뒤, 출하 가능한 제품 수로 나눠 봐야 합니다. 패키징은 칩을 외부 회로와 연결하고 보호하는 작업이고, 교정은 기기마다 조금씩 다른 반응을 측정 기준에 맞추는 과정입니다. 이 두 작업은 칩 안의 소자 수가 늘었다고 자동으로 사라지지 않습니다.
국내 제조기업의 기회도 이 지점에서 찾을 수 있습니다. 광학 정렬을 자동화하는 장비, 칩의 열을 관리하는 패키지, 출하 전에 성능을 빠르게 확인하는 검사 공정이 후보입니다. 이 연구가 특정 기업의 매출로 이어진다는 뜻은 아닙니다. 제품화가 진행될 때 고객이 해결해야 할 작업을 따라가면 보이는 기회입니다.
물류 로봇 10만 대, 매출로 환산할 수 없는 이유
외부 산업 자료를 보면 적용처는 이미 존재합니다. IFR의 World Robotics 2025 발표에 따르면 2024년 운송·물류용 전문 서비스 로봇 판매는 10만2,900대였습니다. 같은 발표의 증가율은 14%입니다. 다만 294개 공급사 표본에 근거한 통계이며, 전 세계 산업 전체를 추정한 수치가 아닙니다. 관련 원문
이 판매량에 센서 가격을 곱해 새 라이다의 시장규모로 계산하면 안 됩니다. 로봇마다 필요한 센서 수가 다르고, 카메라나 다른 거리 센서 조합으로 일을 수행할 수도 있습니다. 새 기술이 실제로 경쟁하는 대상은 고객이 이미 쓰고 있는 전체 인식 시스템입니다.
필자의 판단으로는 작업 범위가 정해진 물류 현장이 초기 검증 후보입니다. 이동 경로와 속도를 제한할 수 있어 센서의 성능을 필요한 작업에 맞춰 평가하기가 상대적으로 쉽습니다. 그렇다고 이번 시제품이 창고에서 검증됐다는 뜻은 아닙니다. 검은 포장재, 반짝이는 랙, 가려진 물체를 놓치지 않는지 현장 자료가 필요합니다.
생산성 향상은 센서가 빠르다는 말보다 로봇이 불필요하게 멈추는 시간이 줄었는지로 확인해야 합니다. 정지가 줄고 사람이 개입하는 횟수가 감소한다면 같은 인력과 장비로 더 많은 물건을 옮길 수 있습니다. 반대로 교정이나 청소 때문에 정지가 늘면 싼 센서가 비싼 운영비를 만들 수도 있습니다.
새 시장이 열린다면 자동화 투자비를 감당하기 어려웠던 작은 작업장까지 도입 범위가 넓어지는 형태일 수 있습니다. 그러나 센서 외에 안전 설계와 현장 소프트웨어, 유지보수 비용도 내려가야 합니다. 산업 대체 역시 기존 라이다 전체가 사라지는 그림보다는, 일부 개별 광학 부품과 조립 작업이 통합 모듈과 검사 서비스로 옮겨 가는 그림이 더 현실적인 가설입니다.
LG이노텍의 투자 발표가 알려주는 것과 알려주지 않는 것
기업 투자 사례도 있습니다. Aeva는 2025년 7월 29일 LG이노텍과 협력을 발표하며 최대 약 5,000만 달러 규모의 지분·신제품 개발·생산설비 투자를 설명했습니다. 이는 당시 발표된 투자 패키지이며, 전액이 집행됐다는 확인 자료로 쓰지는 않았습니다. 관련 원문
관련 기업이 기술개발뿐 아니라 제조 역량 확보에 자금을 배정한다는 점은 의미가 있습니다. 다만 Aeva의 상용 플랫폼과 이번 imec 논문은 별개입니다. 이 발표로 논문 기술의 채택이나 라이선스 계약을 주장할 수 없습니다. 한국 기업이 참여하는 산업의 방향을 보여주는 참고 사례로만 봐야 합니다. 관련 원문
연구가 사업으로 가까워졌다는 다음 증거는 더 큰 숫자의 시연만은 아닙니다. 같은 시야와 표적 조건에서의 검출 성능, 출하 가능한 수율, 모듈 한 개의 검사 시간, 고객 현장의 중단시간이 공개돼야 합니다. 어느 항목을 개선했는지에 따라 이익을 얻는 기업도 달라집니다.
실리콘 포토닉스 라이다의 이번 성과는 빛을 보내는 방식과 받는 방식을 함께 설계할 선택지를 넓혔다는 데 있습니다. 로봇 센서값을 낮추는 길은 열렸지만, 그 길의 비용은 아직 계산되지 않았습니다. 앞으로 볼 숫자는 최대 거리와 함께, 정상 작동하는 모듈 한 개를 만들어 현장에서 유지하는 데 드는 총비용입니다.
자료 확인 기준일은 2026년 9월 25일입니다. 기업 사례는 기술·산업 분석을 위한 것이며 특정 종목의 매수나 매도를 권하는 내용은 아닙니다.
로봇 센서의 경제성은 정상 작동하는 모듈을 만들어 현장에서 유지하는 총비용으로 확인해야 합니다.
출처와 참고 링크
The work was published in Nature Communications on September 4, 2026, by researchers at imec and Tyndall. The available paper is a peer-reviewed, accepted article awaiting final editing. Experimental findings, industry evidence and the economic interpretation below have different levels of certainty. Primary source
What changes in silicon photonics LiDAR?
LiDAR sends light toward objects and uses the returning signal to locate them. Silicon photonics builds optical paths and components into a semiconductor chip. Its manufacturing appeal is the ability to fabricate many optical functions together rather than assemble every function separately. Primary source
FMCW, or frequency-modulated continuous-wave sensing, varies the frequency of a continuous laser signal. Comparing the return with reference light reveals range and motion toward or away from the sensor. That is radial velocity, not a complete measurement of motion in every direction. Primary source
Chip-based LiDAR already has a substantial research history. A 2022 Nature paper demonstrated silicon photonic LiDAR using microscopic mechanical switches. The new work should be judged by its transmitter–receiver architecture, rather than presented as the invention of LiDAR on a chip. Primary source
The transmitter is an optical phased array, or OPA, which steers light by controlling the relative phases of optical waves. The receiver is a focal-plane array, or FPA, behind a collecting lens. Separating the transmit and receive paths lets each perform a different job and removes the need for an optical circulator. Primary source
OPA transmitter
Steer the outgoing light
Job
Method · Control optical phase
FPA receiver
Collect and detect returns in parallel
Job
Method · Lens and detector array
The engineering idea is a division of labour. Efficient transmission and efficient collection do not necessarily demand the same optical geometry. Fabricating complementary functions together can relax a design compromise. Whether this also lowers cost is a separate manufacturing question.
Read the demonstration conditions before the headline numbers
The demonstrated point-cloud rate was 10 frames per second. A point cloud represents a scene as spatial coordinates. The 41 fps figure comes from a timing budget for an implementation that removes computer-side processing and transfer overhead. These are a measured result and a conditional projection, not two equivalent product benchmarks. Primary source
Not equivalent measurements. The 41 fps timing estimate assumes removal of computer-side bottlenecks. Source: paper pp.2,5.
The 20-metre test used a 3.6° by 1.8° field of view. A separate one-metre demonstration used 16° by 8°. Field of view describes how much of the scene the sensor covers. Combining the longer range and wider view into a single specification would misrepresent the experiments. Primary source
Near-range demonstration
1 m
Range
Field of view · 16° × 8°
Lens focal length · 8 mm
Longer-range demonstration
20 m
Range
Field of view · 3.6° × 1.8°
Lens focal length · 35 mm
The reported 3.7 mW is emitted optical power, not total electrical consumption. The prototype still needs a laser, processing electronics and thermal control. Its five-centimetre depth resolution is also not a guarantee of that accuracy on every surface and in every environment. Primary source
These distinctions matter to a buyer. If an aisle requires broad coverage but a sensor sees only a narrow area, the installation may need additional sensors or a different layout. A cheaper chip does not guarantee a cheaper deployed system. This is an economic implication of the experimental boundaries, not a result measured in the paper.
The cost question sits in assembly and testing
The paper is not a business case with a selling price or factory cost model. The economic analysis therefore starts with tasks that integration might remove, rather than an invented percentage cost reduction.
An optical module requires more than attaching parts. Optical paths must line up, and measurements must remain usable as conditions change. Defining some relative positions during chip fabrication could reduce repetitive alignment work during assembly. The saving would need to be demonstrated on a production line.
Integration also concentrates risk. A defect in one function can compromise a more valuable combined device. Yield is the share of manufactured devices that meet requirements. Poor yield or lengthy optical testing can consume the savings from simpler assembly.
-
1
Integrate optical functions
Define some relative positions during fabrication
-
2
Potentially simplify assembly
Measure actual alignment and connection savings
-
3
Account for yield and testing
Defects and calibration may offset savings
-
4
Compare cost per saleable module
Include deployment and maintenance
A meaningful quote includes packaging, calibration, testing and warranty costs per saleable module. Packaging connects and protects the chip. Calibration corrects differences between individual devices. Neither disappears simply because more optical functions have been integrated.
For Korean manufacturers, potential opportunities include automated optical alignment, thermal packaging and faster end-of-line inspection. This is not a revenue forecast for any named company. It identifies work a product developer would have to complete before shipping a dependable sensor.
Logistics offers a use case, not an automatic sales forecast
There is an existing application market. IFR’s World Robotics 2025 release recorded 102,900 transportation and logistics service robots sold in 2024, up 14%. Those figures come from a sample of 294 service-robot suppliers, not an estimate projected to the entire industry. Primary source
Multiplying that robot count by a sensor price would not establish this technology’s addressable market. Sensor counts vary, and existing machines can use cameras or other ranging systems. The competitor is the customer’s installed perception system, including its software and operating history.
A bounded logistics task looks like a plausible early validation setting. Routes and speeds can be constrained, allowing performance to be matched to a specific job. That is an inference, not evidence of a warehouse trial. Dark wrapping, shiny racks and occluded objects would still require field testing.
Productivity should be measured through unnecessary stops and human interventions, not sensor speed alone. Fewer interruptions could allow the same workforce and equipment to move more goods. Extra calibration or cleaning could reverse the benefit. The paper does not quantify either outcome.
A possible new market is smaller facilities that cannot justify today’s automation costs. That requires progress in safety engineering, site integration and maintenance as well as sensing. A more plausible displacement hypothesis is a shift from some discrete optical components and assembly tasks toward integrated modules and testing services, rather than wholesale replacement of existing LiDAR.
What the LG Innotek announcement does—and does not—show
A concrete investment example comes from Aeva’s July 29, 2025 announcement of a collaboration with LG Innotek. It described a package of up to approximately $50 million covering equity, product development and production capacity. This is evidence of an announced commitment, not verification that the entire amount has been spent. Primary source
The useful signal is that companies are allocating resources to manufacturing as well as sensing technology. Aeva’s commercial platform is separate from the imec research. The announcement does not establish adoption of this paper, a licence agreement or a commercial relationship with its authors. Primary source
The next commercial evidence should include detection performance under matched target and coverage conditions, saleable yield, testing time per module and downtime at customer sites. These measures reveal whether value accrues to chip designers, module makers or system operators.
This silicon photonics LiDAR expands the design options for combining transmission and reception. It offers a route toward simpler sensing hardware, while leaving the cost of that route unresolved. Alongside maximum range, watch the total expense of producing a working module and keeping it working in the field.
Sources were checked as of September 25, 2026. Company examples illustrate technology and industry structure; they are not recommendations to buy or sell securities.
Measure the cost of producing a working sensor module and keeping it working in the field.
Sources and further reading
이 글은 정보 제공 목적이며, 특정 자산의 매수·매도를 권유하지 않습니다.
For information only — this is not a recommendation to buy or sell any asset.
댓글Comments 0